nature will · Launch Video Breakdown: Hook, Pacing & Motion Design
First general foundation model for the physical world
Scene-by-scene timeline & spoken transcript
The Hook
Introduction to Natura-1 Autonomous Foundation Model
“We're introducing Natura-1. These clips come from longer autonomous demonstrations.”
- On screen
- autonomous, 1x nature will We're introducing Natura-1 These clips come from longer autonomous demonstrations
- Camera
- Frontal static eye-level framing on humanoid robot in warm domestic kitchen environment.
- Motion
- Direct hard cut to top-down flat-lay food prep shot with persistent corner branding stamps.
Product Reveal
Dexterous Food Preparation and Culinary Bimanual Control
“(No spoken dialogue — crisp electronic synth arpeggios pulsing over 128 BPM four-on-the-floor kick with mechanical servo foley.)”
- On screen
- autonomous, 2x nature will
- Camera
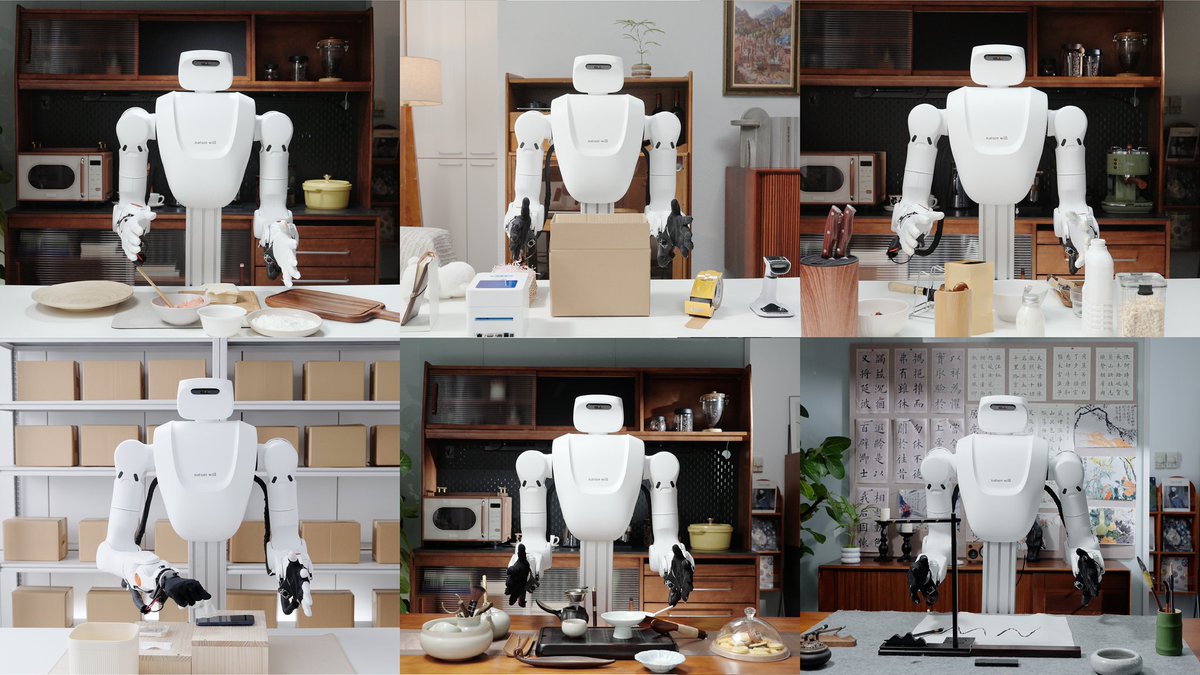
- Triptych split screen combining overhead flat lay, 45-degree isometric side view, and wide frontal framing.
- Motion
- Synchronized multi-angle layout tracking fine dumpling folding and banana cutting at 2x playback speed.
Feature Teaser
Industrial Packing, Assembly, and Delicate Calligraphy
“(No spoken dialogue — ascending synth riser dropping into punchy 808 sub-bass accents synchronized to packaging actions.)”
- On screen
- autonomous, 2x nature will
- Camera
- Triptych multi-camera view showcasing box taping, phone accessory fitting, and fine ink brushwork.
- Motion
- Precision multi-panel geometric grid demonstrating cross-domain physical fine motor skills.
Feature Teaser
Zero-Shot Generalization and Natural Language Interaction
“Zero-shot generalization and instruction following is another key capability of Natura-1.”
- On screen
- Zero-shot generalization and instruction following nature will autonomous, 1x objects and actions
- Camera
- Clean black title screen transition cutting to top-down suitcase packing and bottle sorting.
- Motion
- Minimalist centered typographic title card followed by unedited 1x real-time pick-and-place tracking.
Feature Teaser
Nine-Screen Live Voice Instruction Evaluation
“Pick up the bottle. Put the glasses in the case. Fold the napkin.”
- On screen
- autonomous, 1x nature will
- Camera
- Synchronized 3x3 video matrix showing an engineer sitting across from the robot giving real-time prompts.
- Motion
- Nine-panel simultaneous multi-clip grid highlighting deterministic instruction adherence.
Call to Action
Sixteen-Panel Multi-Task Emergence Matrix
“Unexpected behaviors down to the details that matter to you beyond predefined capabilities.”
- On screen
- Unexpected behaviors nature will autonomous, 3x down to the details that matter to you beyond predefined capabilities
- Camera
- Stark title card transitioning into a massive 4x4 matrix wall displaying simultaneous autonomous skills.
- Motion
- 16-cell synchronized video array demonstrating foundational physical intelligence scaling.
Motion design primitives
Synthesizable in Remotion · key components of the physical-ai-matrix-showcase template.
TriptychLayoutSplit
Divides viewport into one dominant left frame and two stacked right frames with crisp hair-thin borders.
+ Code construction recipe
Compose absolute-positioned Remotion Video elements inside a CSS grid layout with spring-driven opacity fades.
TelemetryBadgeOverlay
Fixed corner typography displaying operational state and speed multiplier tags.
+ Code construction recipe
Render flex container pinned to corners with serif fonts and subtle opacity transitions driven by current frame.
SynchronizedMatrixGrid
Dynamic grid scaling seamlessly from 3x3 to 4x4 panels displaying synchronized video feeds.
+ Code construction recipe
Map array of video feeds inside a CSS grid container using gap tokens and uniform aspect ratio containers.
MinimalTitleScreenCard
Stark black title canvas with center-aligned white serif typography and top-right branding.
+ Code construction recipe
Full-screen absolute div using interpolate on opacity and translateY for smooth 12-frame text entrances.
Style DNA & aesthetic system
Visual aesthetic
Typography
Motion
Special effects
Pacing & rhythm
Conceptual story rhythm
- 1
Physical Reality Hook
Purpose. Establish authentic unedited autonomy in real domestic environments.
Execution. Eye-level 1x humanoid robot framing with persistent status badges.
- 2
Triptych Dexterity Proof
Purpose. Demonstrate micro-precision across varied domestic tasks.
Execution. Three-way split screen linking overhead macro views with frontal context.
- 3
Cognitive Instruction Following
Purpose. Highlight zero-shot reasoning and speech prompt parsing.
Execution. Typographic title card cutting to synchronized multi-angle live interaction.
- 4
Matrix Scale Crescendo
Purpose. Prove generalizability and emergent versatility at scale.
Execution. Dense 9-panel and 16-panel synchronous mosaic grids timed to electronic drops.
Remix in Animatiq Studio
Master remix prompt · agent-ready
Sample remix
Objective
Launch an autonomous micro-surgical robotic assistant.How the recipe adapts
The triptych layout shows endoscopic macro cameras alongside surgeon console angles, corner badges track millimeter latency metrics, and title cards introduce zero-shot anatomical adaptation before closing on a multi-procedure matrix.Remix blueprint · physical-ai-matrix-showcase
Scene durations (6 scenes, 192s)
Key Remotion components
Related AI & ML Product Launches
Explore all AI & ML launches →
Introducing Griffin, the first AI to pass the video Turing test

The most emotive and controllable TTS model

Always-on agents built to handle everything